






Computer Vision & ML Engineer · Computer Vision · Machine Learning · Robotics Perception


I build perception systems that let vehicles and robots understand where they are and what is around them.
- 🔭 Now: Junior Robotics Engineer at Virya Autonomous Technologies (Sep 2025 – Present)
- 🧠 Focus: detection, segmentation, tracking, monocular depth, visual odometry & SLAM on real camera / LiDAR / IMU / GPS data
- 🚀 Ship: from labeling and training to real-time deployment with PyTorch, TensorRT, C++ and ROS 2
- 📄 Research: Vision-Based Odometry: Comparative Analysis on Standard and Custom Datasets for Resource-Limited Vehicle Platforms · 2026 IEEE DISCOVER, Puttur
- 🎓 Education: B.Tech, Electronics & Communication Engineering, GITAM (Deemed to be University), Bengaluru · CGPA 8.55 / 10
- 🎯 Looking for: Computer Vision, Machine Learning and robotics-perception roles
| Project | What it does | |
|---|---|---|
| InfraStructer | Dashcam + phone GPS → road-sign map checked against OpenStreetMap. C++, live at 10 Hz on a laptop GPU, 3.2 m median ATE over 33 KITTI / nuScenes / Oxford drives. | 🔒 private |
| AutoSegmentor | SAM2 + CoTracker3 auto-labeling: annotate one frame, export YOLO detection, segmentation and pose datasets for the whole video. On PyPI. | code |
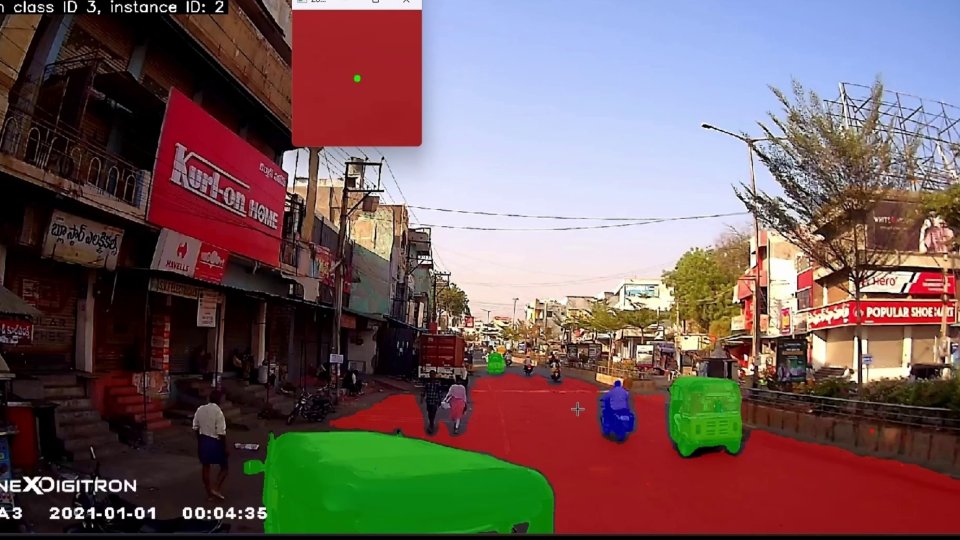
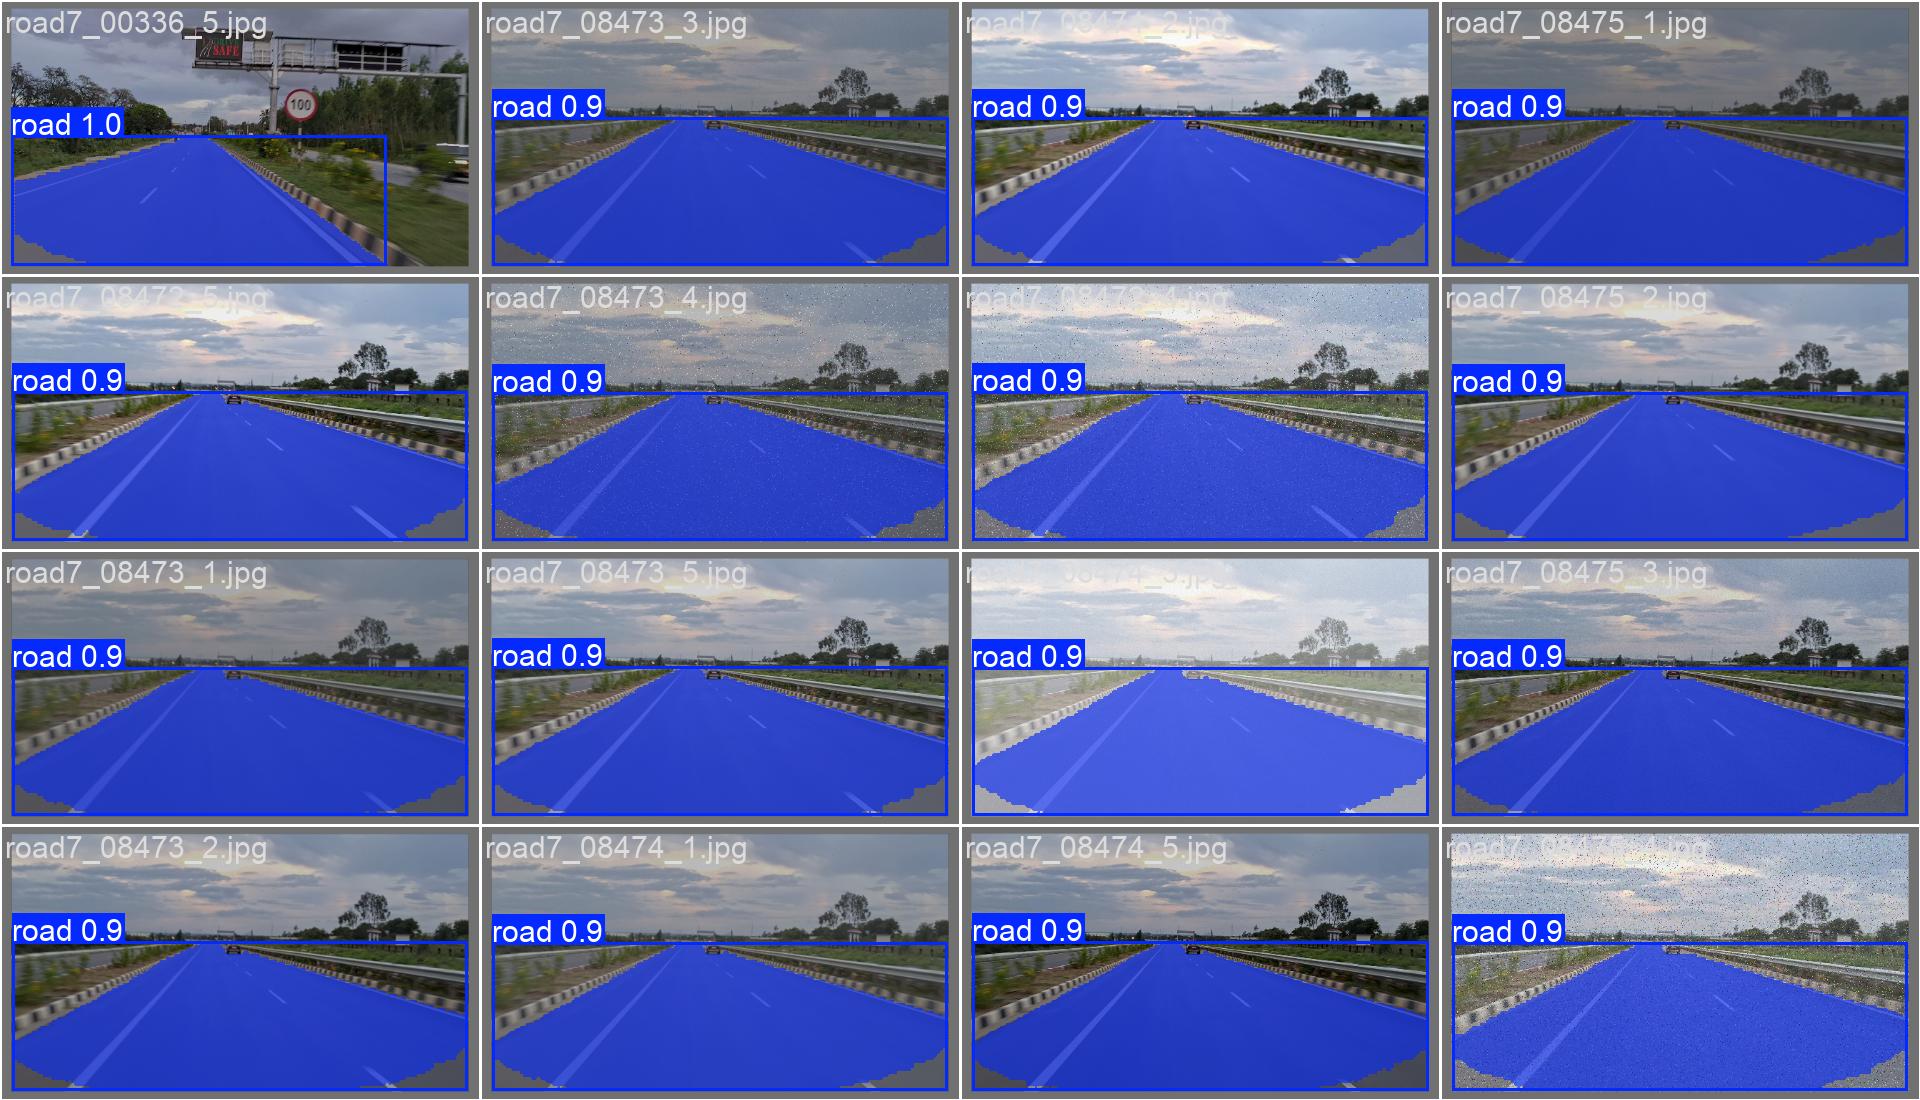
| Drivable-Region & Object Perception for Indian Roads | YOLOv8-Seg drivable-region and object perception for Indian roads, trained on a 45,000+ image dataset I built from 40 videos. | code |
| Visual Odometry Benchmark for Low-Compute Vehicles | Five monocular VO methods (feature, optical-flow, deep) compared on KITTI and a new campus dataset, on a Jetson Xavier NX. IEEE DISCOVER 2026. | code |
| Semantic Robot Perception | ROS 2 robot with YOLO-World open-vocabulary detection, camera–LiDAR fusion and a persistent 3D semantic map. | 🔒 private |


CV & ML projects · Robotics projects · More work · Every repository
🔒 = private repository, code available on request. Generated from the same data as thippeswammy.github.io.